

In automated production lines for machining, stamping, die casting, and other processes, loading and unloading are common applications. Workpieces often vary in position, orientation, and consistency. As production models become more flexible, multiple workpiece types are increasingly processed at the same workstation, with frequent changeovers based on production orders. Traditional fixed tooling and manual robot teaching can no longer meet the demands of flexible manufacturing.
The 3D Vision-Guided Loading and Unloading Solution uses high-quality industrial 3D cameras and application algorithms to acquire the 3D position and orientation of workpieces, automatically locate target parts, and output accurate picking coordinates to the robot for loading operations. The system can also scan and locate trays, racks, and other placement fixtures, guiding the robot to pick parts, adjust their orientation, and complete unloading and placement operations.
Technical Highlights
High-quality 3D imaging, application algorithms, and coordinated robot control enable reliable 3D vision performance in complex industrial environments.
High-quality 3D imaging, application algorithms, and coordinated robot control enable reliable 3D vision performance in complex industrial environments.
High-Precision 3D Positioning
The 3D vision system acquires complete workpiece position and orientation data, continuously providing the robot with accurate and stable picking coordinates.
Adaptation to Complex Workpiece Surfaces
High-adaptability 3D imaging solutions are available for metal parts, castings, black workpieces, and reflective components, improving data acquisition stability.
Support for Multiple Part Feeding Methods
Supports trays, pallets, racks, bins, totes, conveyors, and other feeding methods, reducing dependence on high-precision positioning fixtures.
Automatic Position Deviation Detection
Real-time calculation of positional and rotational deviations caused by transportation, upstream part feeding, and other processes improves correction capability for incoming part variations.
Fast Robot System Integration
The 3D vision system acquires complete workpiece position and orientation data, continuously providing the robot with accurate and stable picking coordinates.
Multi-Workpiece Compatibility
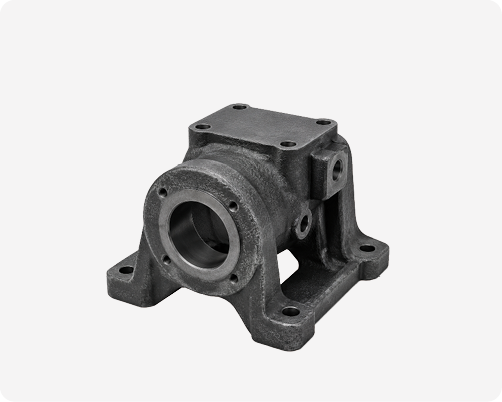 Castings
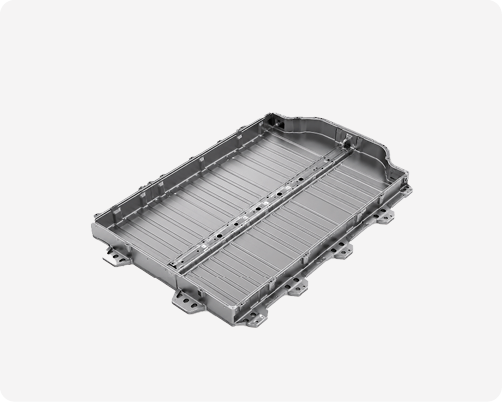 Gigacastings
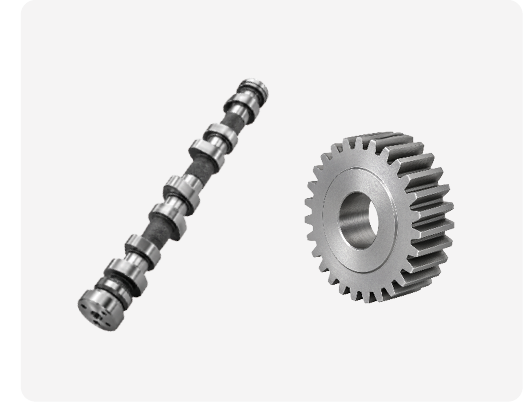 Shafts & Gears
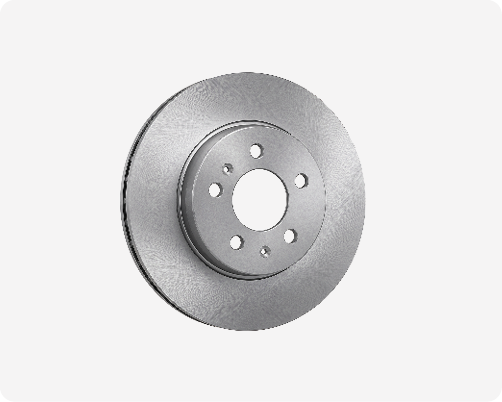 Disc-Type Parts
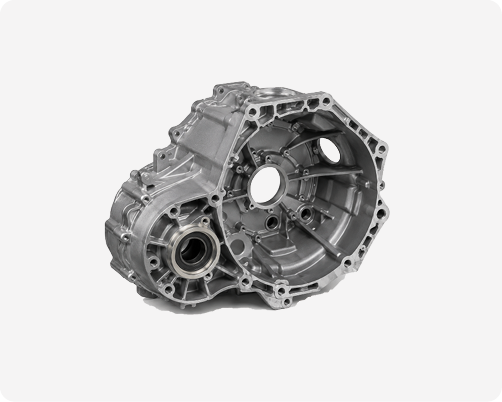 Housing Parts
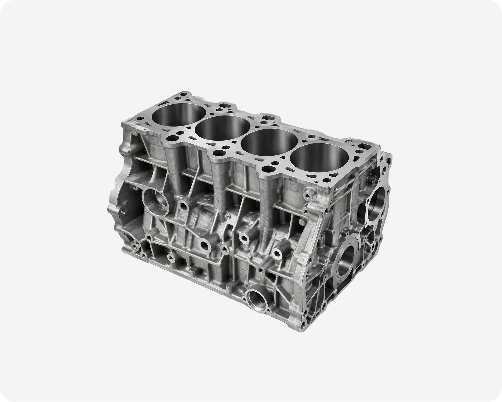 Powertrain Components
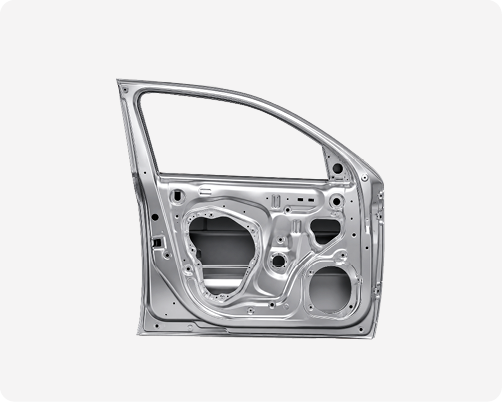 Stamped Parts
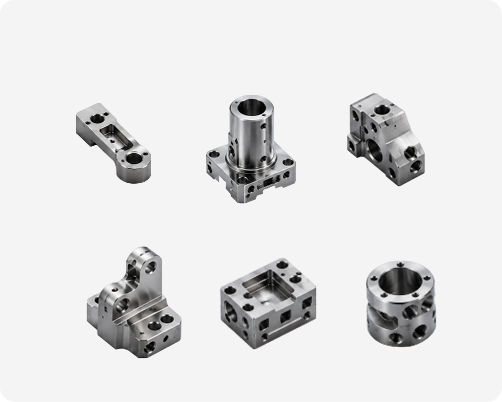 Complex Precision Parts
Flexible Part Feeding Support
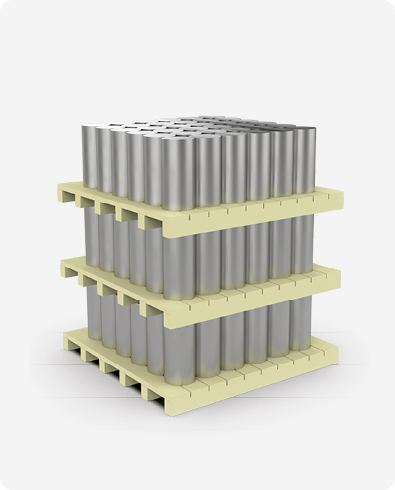 Multi-Layer Pallets
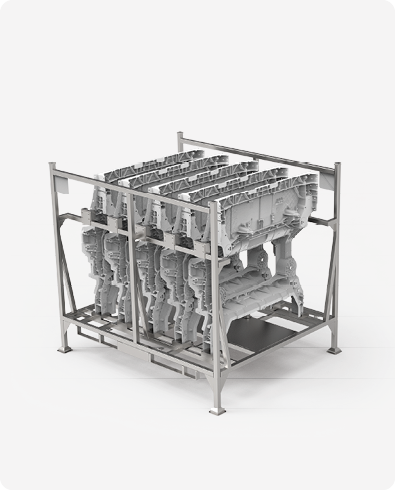 Metal Racks
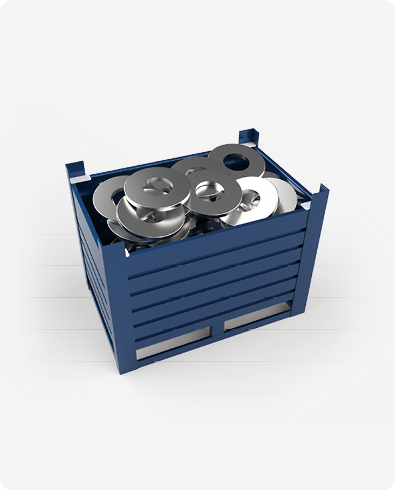 Metal Bins
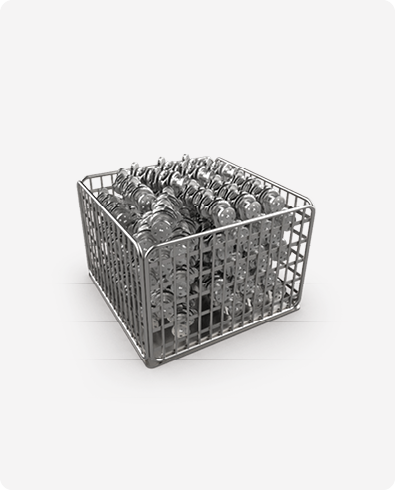 Collapsible Wire Basket
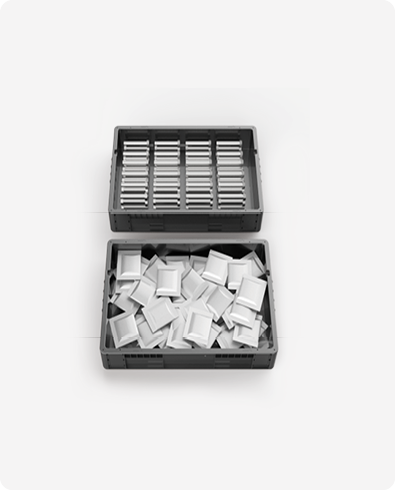 Plastic Tote Bins
Robust Workpiece Matching

3D camera captures the original workpiece point cloud

Match with the established workpiece template

Calculate robot loading and unloading coordinates
Fast Positioning for Symmetrical Parts


Detect the center of a circular feature for direct fitting and picking.

Identify cylindrical-like features for direct fitting and picking.
Recommended 3D Camera Models


Solution Application Cases


